


















After the filling barrels are placed on the conveyor belt of the conveying mechanism, the conveying motor starts and transports the filling barrels to the filling position. When it reaches the filling position, the proximity switch detects the filling barrel and transmits the sensing signal to the PLC. The PLC controls the conveying motor to stop, and the lifting cylinder starts to rise under the control of the PLC. At the same time, the roller arm structure rises to the maximum position within the cylinder's stroke. The lifting cylinder stops rising, and the synchronous motor starts to operate to drive the roller arm to move. The filling barrel can rotate under the带动 of the roller arm.

 020-34563445
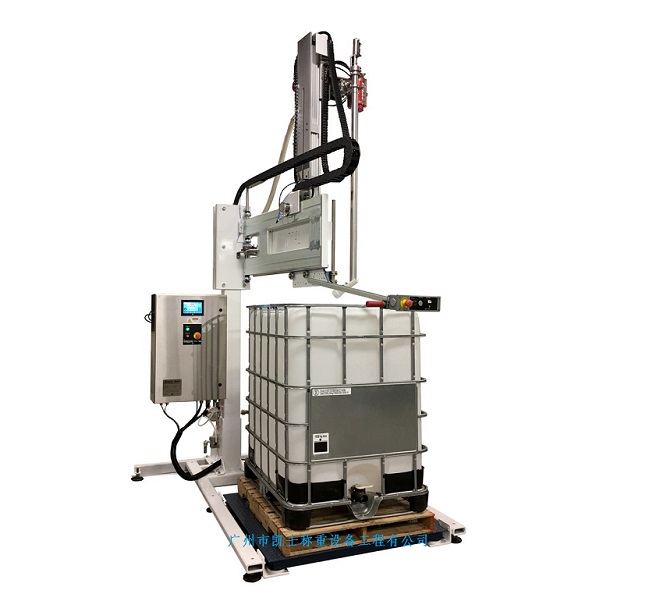
The tank liquid scale is based on the on-site management and control system of the weighing scale technology. It can conduct real-time and effective control of material filling, realize real-time detection of filling weight and real-time opening and closing of the solenoid valves during the filling process, and upload data for effective microcomputer management. It mainly includes an Electronic scale, control part, display circuit part, solenoid valve execution circuit part, upper computer database processing part. It uses high-precision electronic scales and high-precision pulse generators, programmable control PLC and color touch screen. The Filling system control and settings are all intuitively displayed on the touch screen. There are fast and slow two-speed filling, using a single pump and single variable frequency control. Both volume and mass measurement methods can be freely converted. The filling and adjustment are convenient and fast. On the touch screen, any switch can control any filling head. If there is a fault, it can be directly turned off without affecting the normal use of other filling heads.
After the filling barrels are placed on the conveyor belt of the conveying mechanism, the conveying motor starts and transports the filling barrels to the filling position. When it reaches the filling position, the proximity switch detects the filling barrel and transmits the sensing signal to the PLC. The PLC controls the conveying motor to stop, and the lifting cylinder starts to rise under the control of the PLC. At the same time, the roller arm structure rises to the maximum position of the cylinder's stroke. The lifting cylinder stops rising, and the synchronous motor starts to operate to drive the roller arm to move. The filling barrel can rotate under the drive of the roller arm. Since the filling barrel is an eccentric barrel, the photoelectric sensor above the barrel mouth and the filling head are both on the circle of the barrel mouth's rotation trajectory. Therefore, when the filling barrel rotates to the position directly below the photoelectric sensor, the photoelectric sensor senses the edge of the barrel mouth of the filling barrel and transmits the signal to the PLC. The PLC, based on the signal from the photoelectric sensor, stops the movement of the synchronous motor. When the barrel mouth is detected, the cap suction device rotates to the position directly above the barrel mouth of the filling barrel under the drive of the cylinder, and sucks the cap of the filling barrel. After completing the cap suction action, it returns to its original position. When the cap is sucked, the quantitative filling process begins. The no-load cylinder controlled by the PLC drives the filling gun to enter the filling barrel for liquid filling. The electronic scale can sense the change in the weight of the filling barrel and connect with the weighing instrument and weighing sensor. On the weighing instrument interface, the center setting can be achieved to realize the quantitative filling of the liquid, and the accuracy of the liquid filling is guaranteed. After the quantitative filling is completed, the weighing instrument will transmit the filling completion signal to the PLC. The PLC, based on this signal, ends the quantitative filling process. The no-load cylinder controlled by the PLC drives the filling gun to rise to the initial position. The cap suction device rotates to the position directly above the barrel mouth of the filling barrel and places the cap on the barrel mouth. The conveying motor starts and transports the filled barrels to the designated position.







